ROVER Control Station
تفاصيل العمل
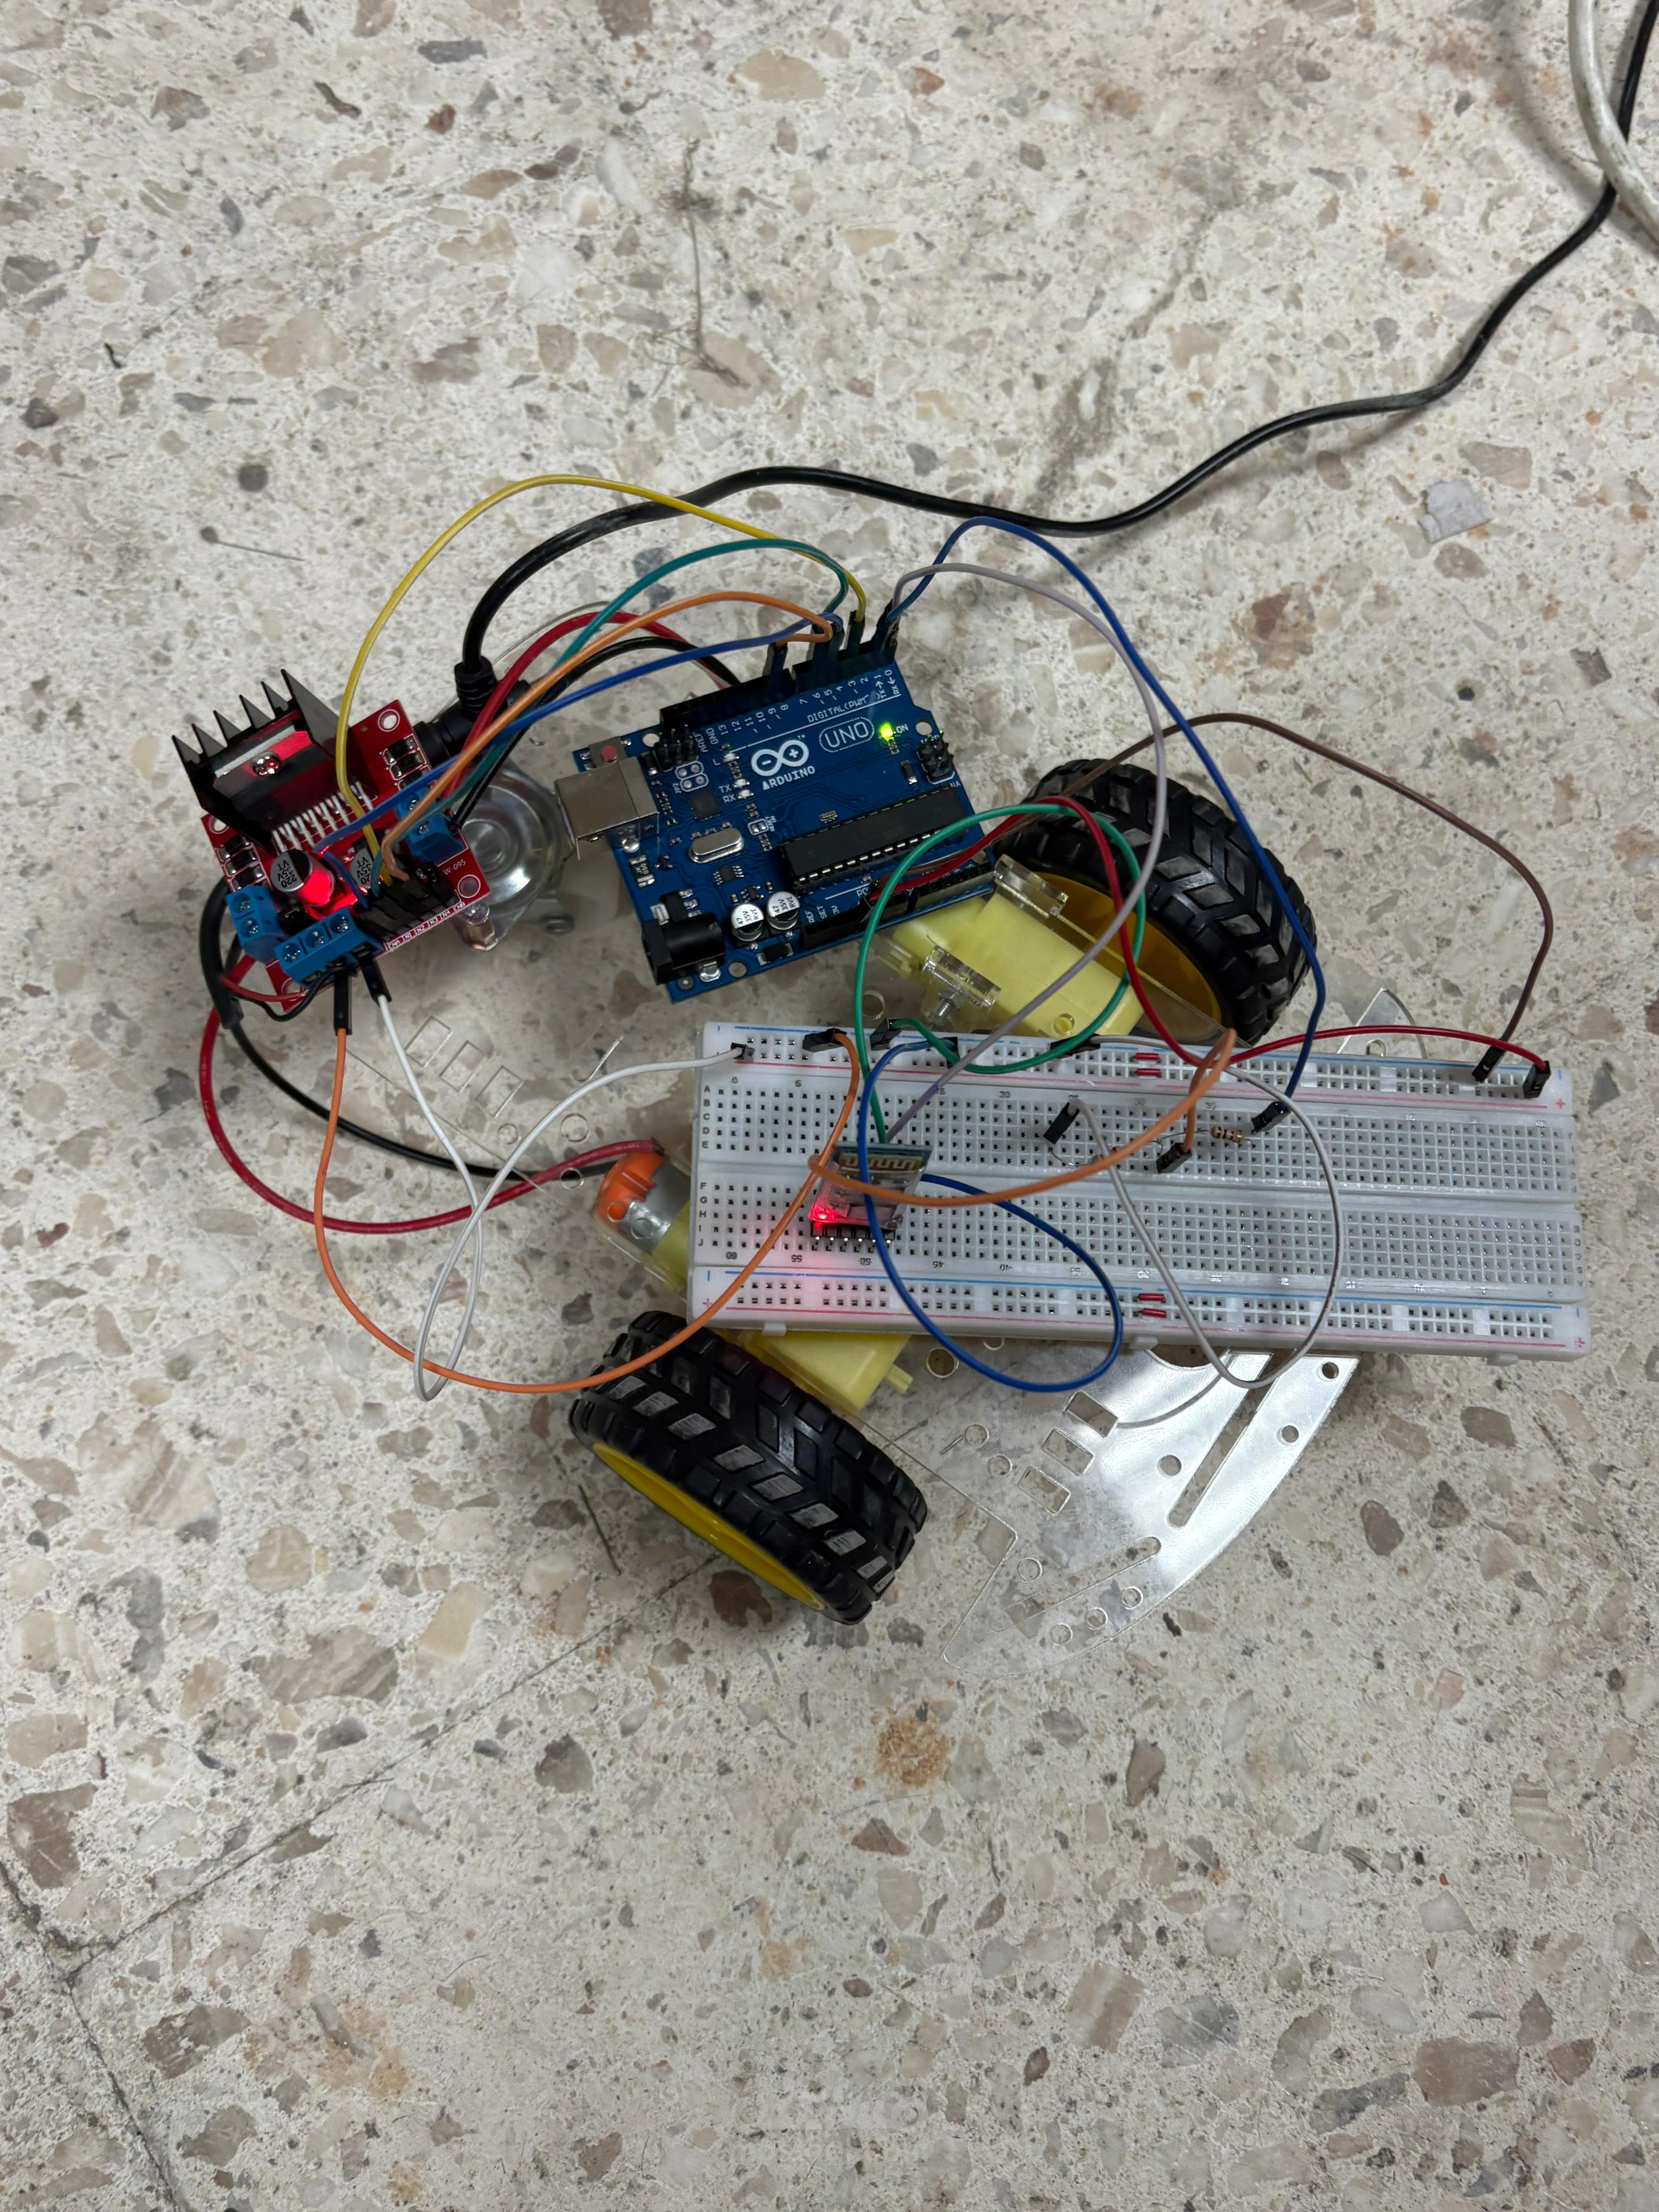
I developed the Front-End interface for a ROVER Control Station as part of a team project.
My main responsibility was designing and implementing the React-based control dashboard and developing the YOLO-based object detection component for autonomous navigation.
The interface provides:
• Real-time camera feed display
• Manual and autonomous control modes
• Motion and speed indicators
• Connection and system status monitoring
• Rover control interface
• Clear visualization of detection and navigation states
For the computer vision part, I trained and tested a YOLO11n model to detect plastic bottles and implemented the detection logic that determines the rover's navigation direction based on the detected object's position.
Technologies used:
React.js, JavaScript, HTML, CSS, Python, YOLO11n, OpenCV
This project gave me practical experience in building a real-time robotics interface and applying computer vision for object detection and autonomous navigation.