Smart Obstacle-Avoiding Robotic Car using Arduino
تفاصيل العمل
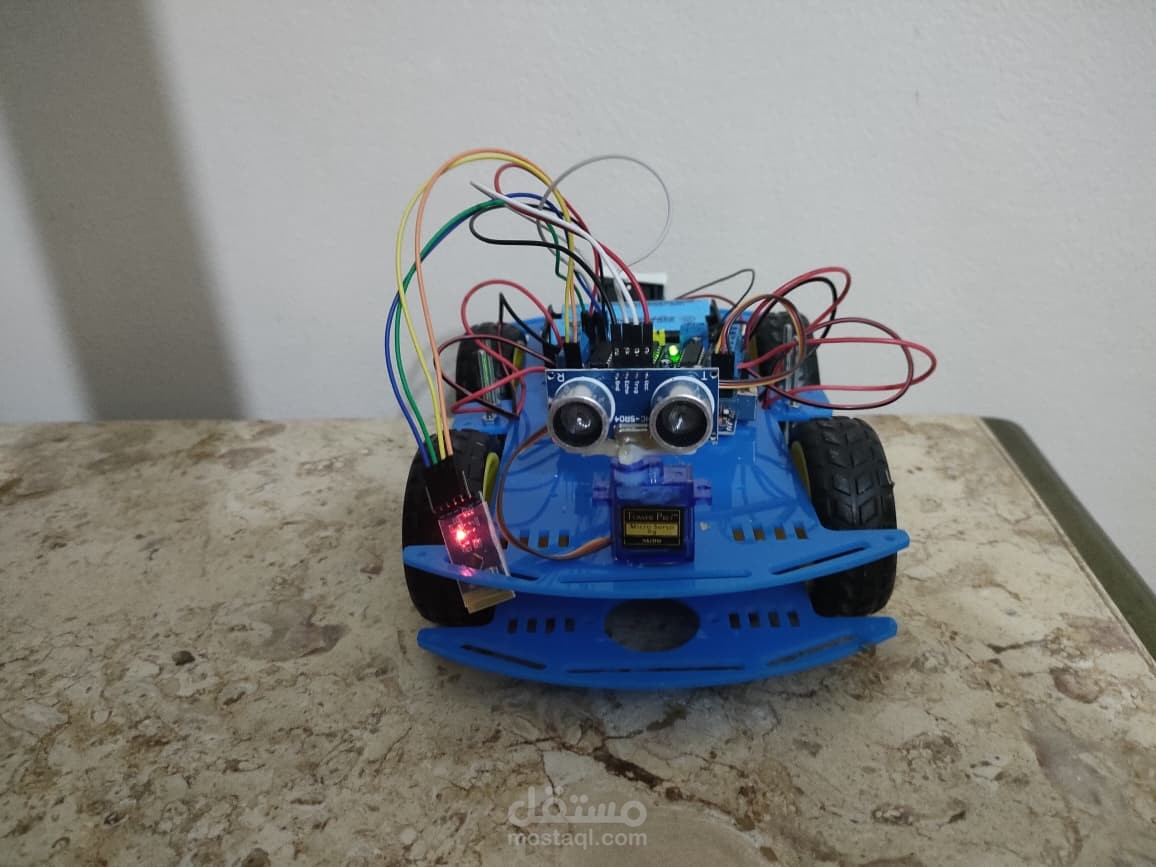
Designed and built an intelligent robotic car powered by Arduino, featuring a **Bluetooth manual control system paired with an automatic safety override for collision avoidance**.
**System Architecture & Core Logic:**
* **Bluetooth Teleoperation:** Controlled manually in real time via a smartphone app using serial Bluetooth communication (HC-05 / JDY-33).
* **Active Collision Override (Autonomous Safety):** While operating under manual control, the ultrasonic sensor (HC-SR04) continuously scans the path. If an obstacle is detected within a critical threshold, the onboard firmware instantly intercepts manual input, executes an autonomous evasion maneuver, and restores control to the user once the path is clear.
* **Motor Control:** Driven by an L293D motor driver shield to handle bidirectional movement, smooth steering, and responsive emergency braking using PWM signals.
* **Robust Firmware:** Programmed in Embedded C++ using non-blocking state logic to ensure zero-latency Bluetooth polling alongside continuous distance measurement.
**Components & Technologies:** Arduino Uno, L293D Motor Shield, HC-SR04 Ultrasonic Sensor, HC-05 / JDY-33, DC Motors, Embedded C++.