Automatic Parking Robot Using ATmega32A
تفاصيل العمل
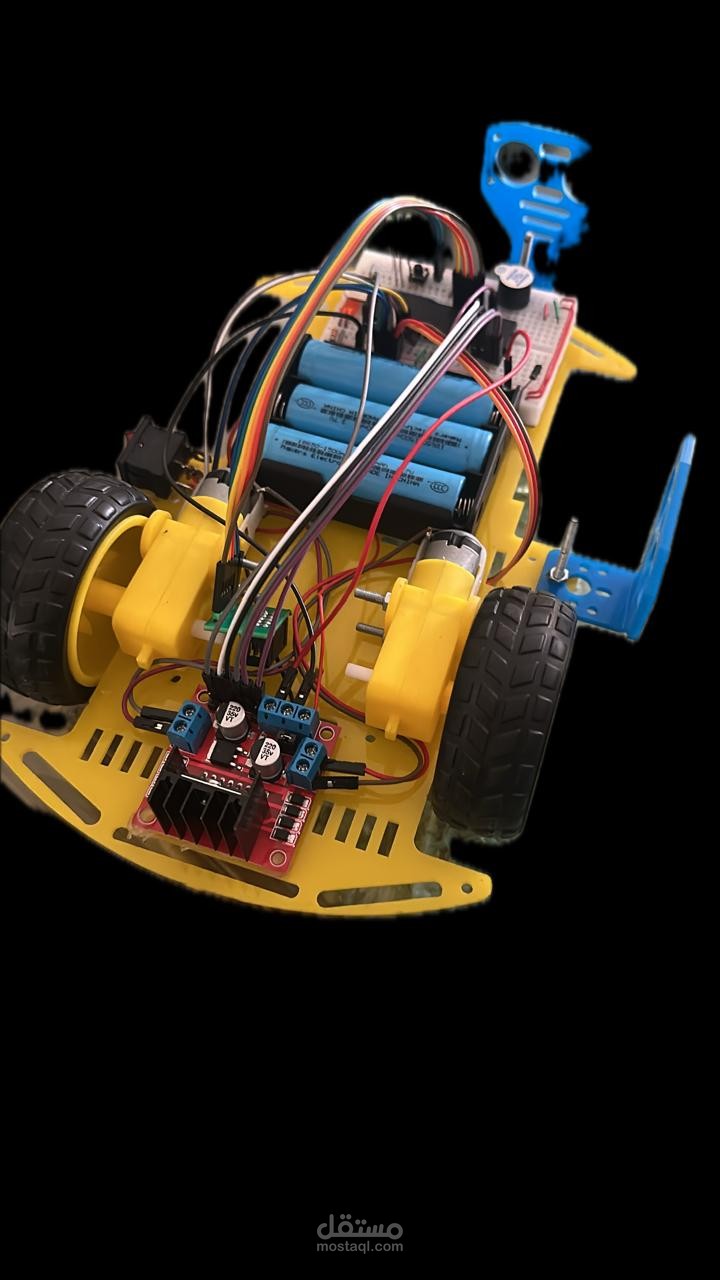
Developed an automatic parking robot using ATmega32A and ultrasonic sensors to detect obstacles and control the robot's movement.
The system was designed to detect obstacles and assist the robot in performing an automatic parking process. The project included microcontroller programming, ultrasonic distance measurement, motor control, and integration of the different hardware components.
The project demonstrates practical experience in Embedded Systems, C programming, Microcontrollers, Sensors, Motor Control, and Robotics.