Line Forwar Car
تفاصيل العمل
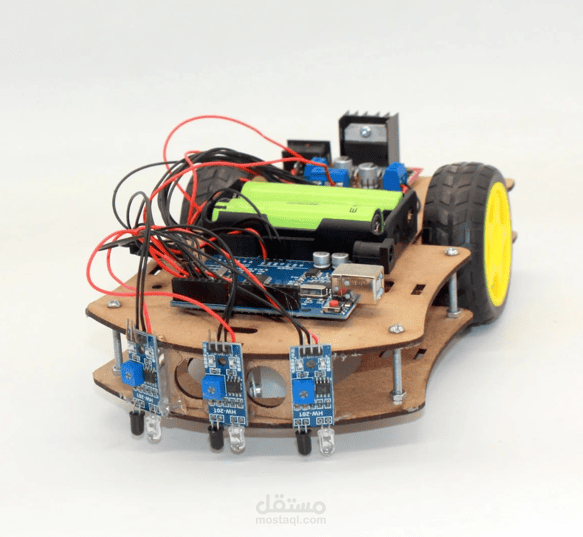
Line Follower Car
Developed a line follower robot car using Arduino and IR sensors. The car detects and follows a predefined path automatically by reading the line through the sensors and controlling the motors accordingly. The project demonstrates basic robotics, sensor integration, Arduino programming, and automated movement control.