ROV Control System
تفاصيل العمل
### ROV Control System – GUI and Hardware Integration
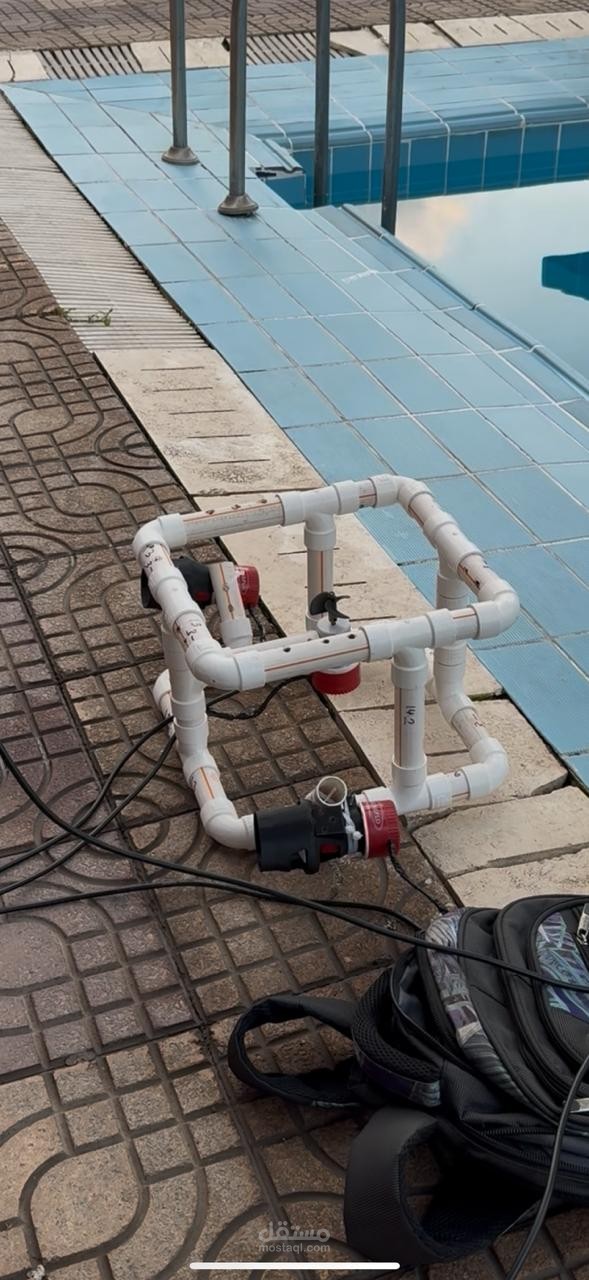
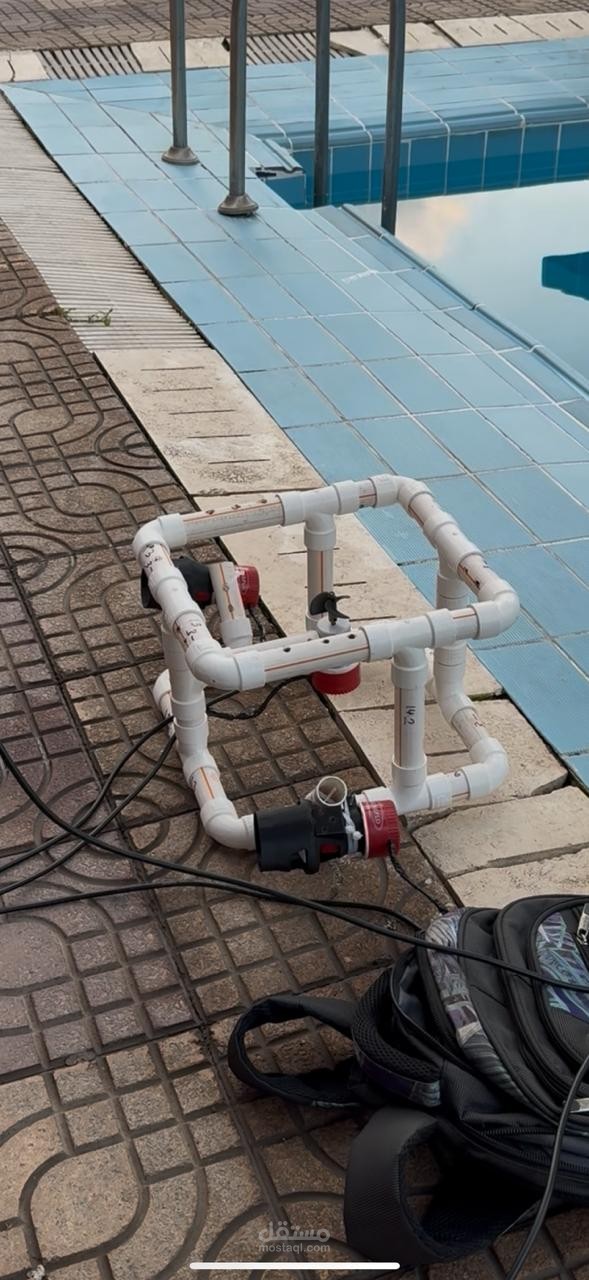
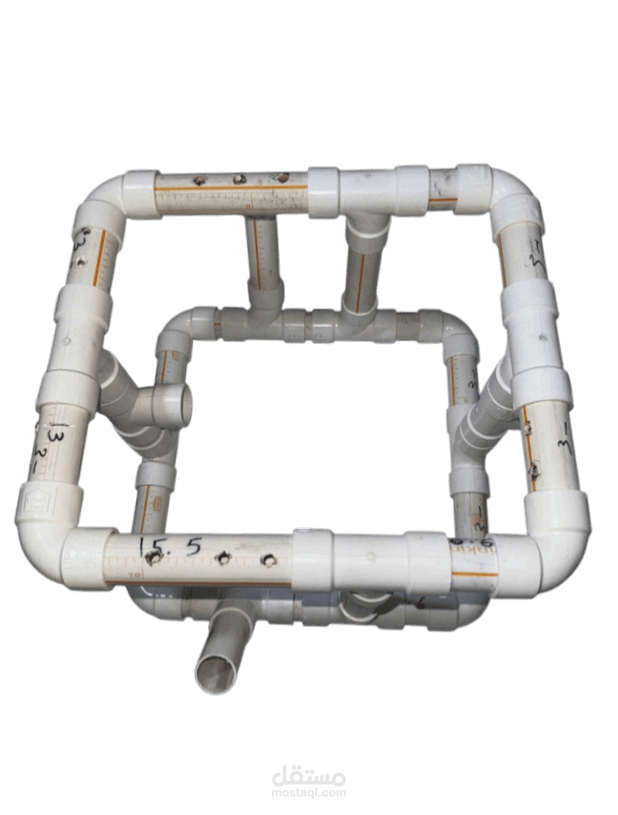
Contributed to the design and development of a **Remotely Operated Vehicle (ROV)** control system as part of a multidisciplinary team.
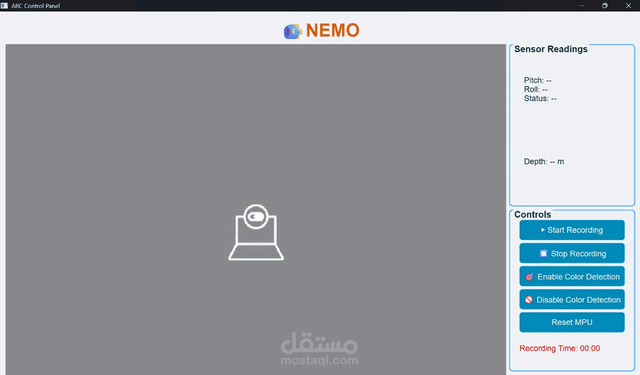
My main responsibility was developing the **Graphical User Interface (GUI)** using **Python and PySide6** in **PyCharm**. The interface was designed to provide the operator with clear controls and real-time information from the ROV.
I also integrated **OpenCV** for computer vision functionality, including processing the camera feed and supporting visual detection tasks. The GUI was connected with the ROV's control and sensor systems to allow the operator to monitor and interact with the vehicle.
In addition to the software development, I contributed to the **electrical wiring, hardware assembly, and integration of the ROV's components**, helping connect the hardware with the control system.
I also worked with a teammate on **preparing and writing the project report**, documenting the system design, implementation, components, and development process.
### Tools and Technologies
* **Python**
* **PySide6** – GUI development
* **OpenCV** – Computer vision and camera processing
* **PyCharm** – Development environment
* **Arduino and sensors** – ROV monitoring and control
* **Git/GitHub** – Project code management
* **Electrical wiring and hardware integration**
### نظام التحكم في المركبة الموجهة عن بُعد (ROV)
ساهمت في تصميم وتطوير نظام تحكم لمركبة موجهة عن بُعد **(ROV)** ضمن فريق متعدد التخصصات.
كان دوري الأساسي هو تطوير **واجهة المستخدم الرسومية (GUI)** باستخدام **Python وPySide6** من خلال بيئة التطوير **PyCharm**. تم تصميم الواجهة لتوفير أدوات تحكم واضحة للمشغل وعرض البيانات والمعلومات القادمة من المركبة بشكل مباشر.
كما قمت بدمج مكتبة **OpenCV** الخاصة بالرؤية الحاسوبية لمعالجة بث الكاميرا وتنفيذ مهام مرتبطة بالكشف والمعالجة البصرية. وتم ربط الواجهة مع أنظمة التحكم وأجهزة الاستشعار الخاصة بالمركبة، مما يسمح للمشغل بالتحكم في المركبة ومتابعة بياناتها.
بالإضافة إلى تطوير البرمجيات، ساهمت في **توصيل الدوائر والأسلاك، وتجميع المكونات الإلكترونية والميكانيكية، ودمج مكونات الـROV مع نظام التحكم**.
كما عملت مع أحد أعضاء الفريق على **إعداد وكتابة تقرير المشروع**، والذي تضمن توثيق تصميم النظام، والمكونات المستخدمة، وطريقة التنفيذ، ومراحل تطوير المشروع.
### الأدوات والتقنيات المستخدمة
* **Python**
* **PySide6** – لتطوير واجهة المستخدم الرسومية
* **OpenCV** – لمعالجة الكاميرا والرؤية الحاسوبية
* **PyCharm** – بيئة تطوير المشروع
* **Arduino وأجهزة الاستشعار** – للتحكم ومتابعة بيانات الـROV
* **Git/GitHub** – لإدارة ملفات وكود المشروع
* **التوصيلات الكهربائية وتجميع ودمج المكونات**