Autonomous Self-Balancing Mobile Robot with Environmental Telemetry
تفاصيل العمل
Project Overview
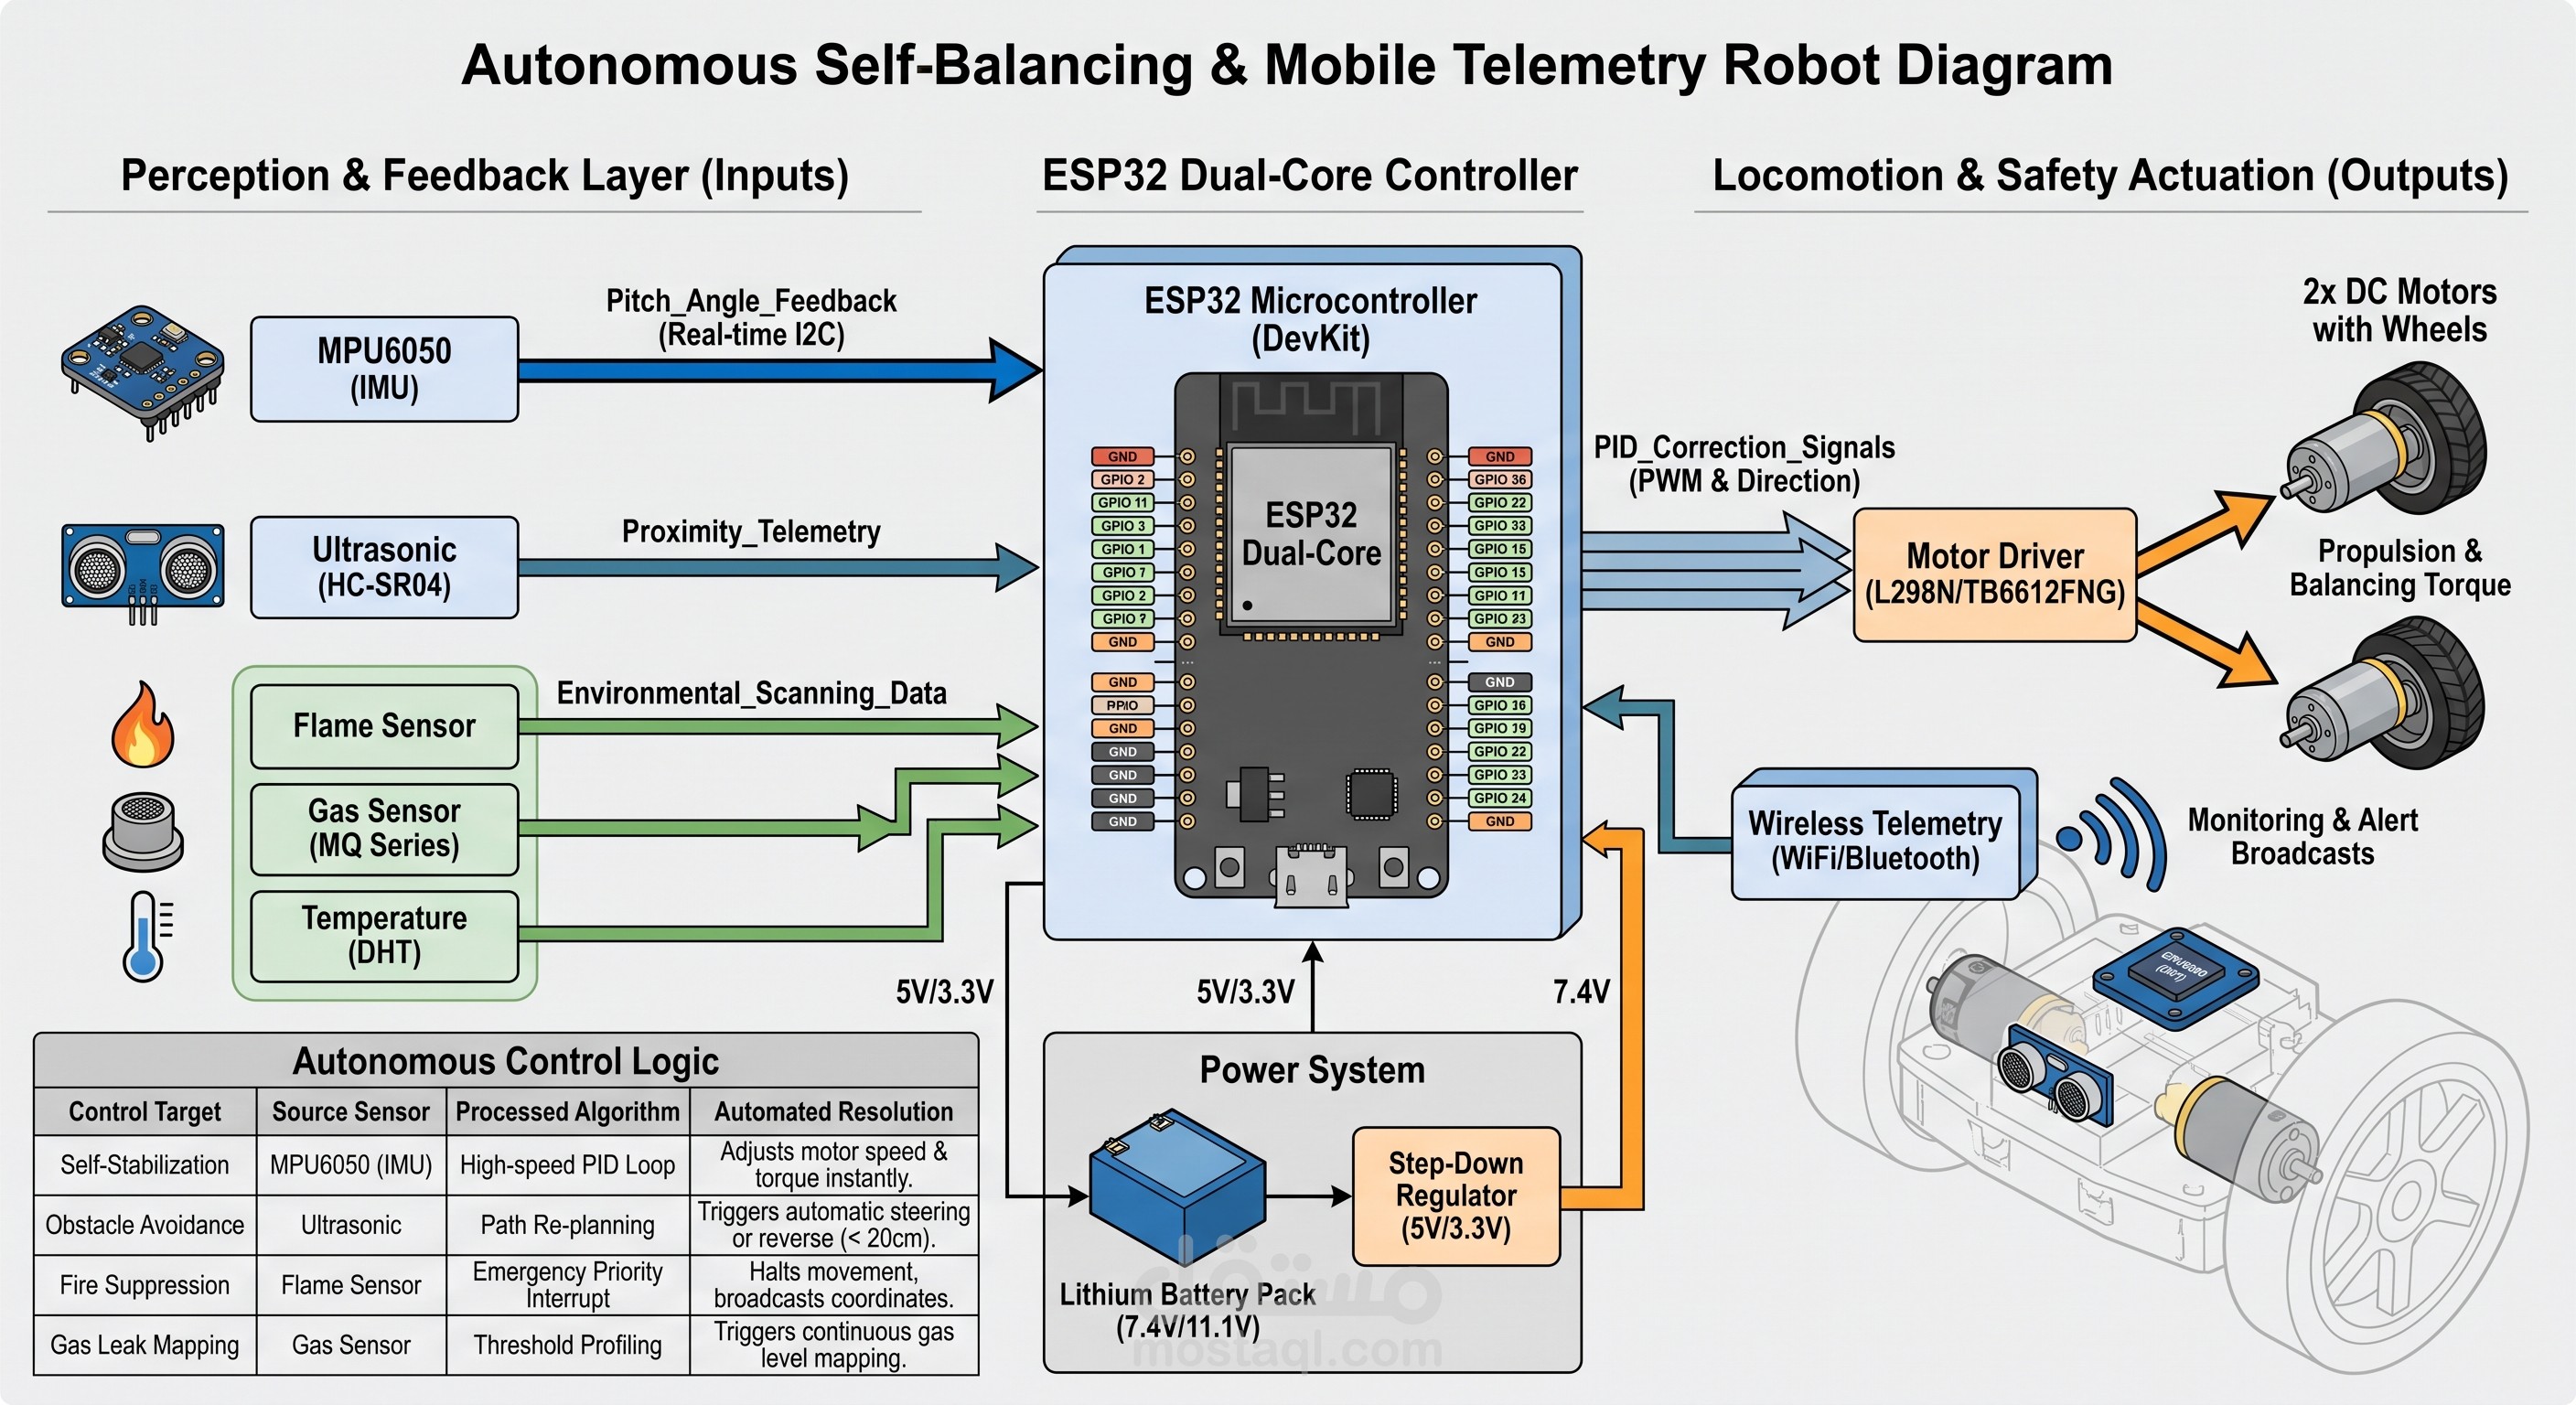
Constructed a highly dynamic, two-wheeled autonomous robotic platform capable of self-stabilization, intelligent obstacle avoidance, and mobile environmental inspection.
Technical Implementation
Core Processing: ESP32 microcontroller selected for high-speed control loops and dual-core processing capabilities.
Control & Stabilization: Utilized IMU feedback loop combined with precise control algorithms (PID-ready) to dynamically adjust DC dual-motor speeds via a dedicated Motor Driver, maintaining perfect vertical balance.
Navigation & Safety: Embedded an Ultrasonic sensor for automated real-time path planning and obstacle avoidance.
Environmental Scanning: Equipped the mobile unit with Gas, Flame, and Temperature sensors to map and detect ambient hazards while in motion.
Key Outcomes
Developed a responsive closed-loop feedback control system ensuring the robot remains upright during motion and external disturbances.
Engineered a truly multi-functional robotic agent capable of mapping hazardous zones entirely autonomously.