Hardware-in-the-Loop (HIL) Navigation Simulator with Kalman Filter Integration
تفاصيل العمل
Project Overview
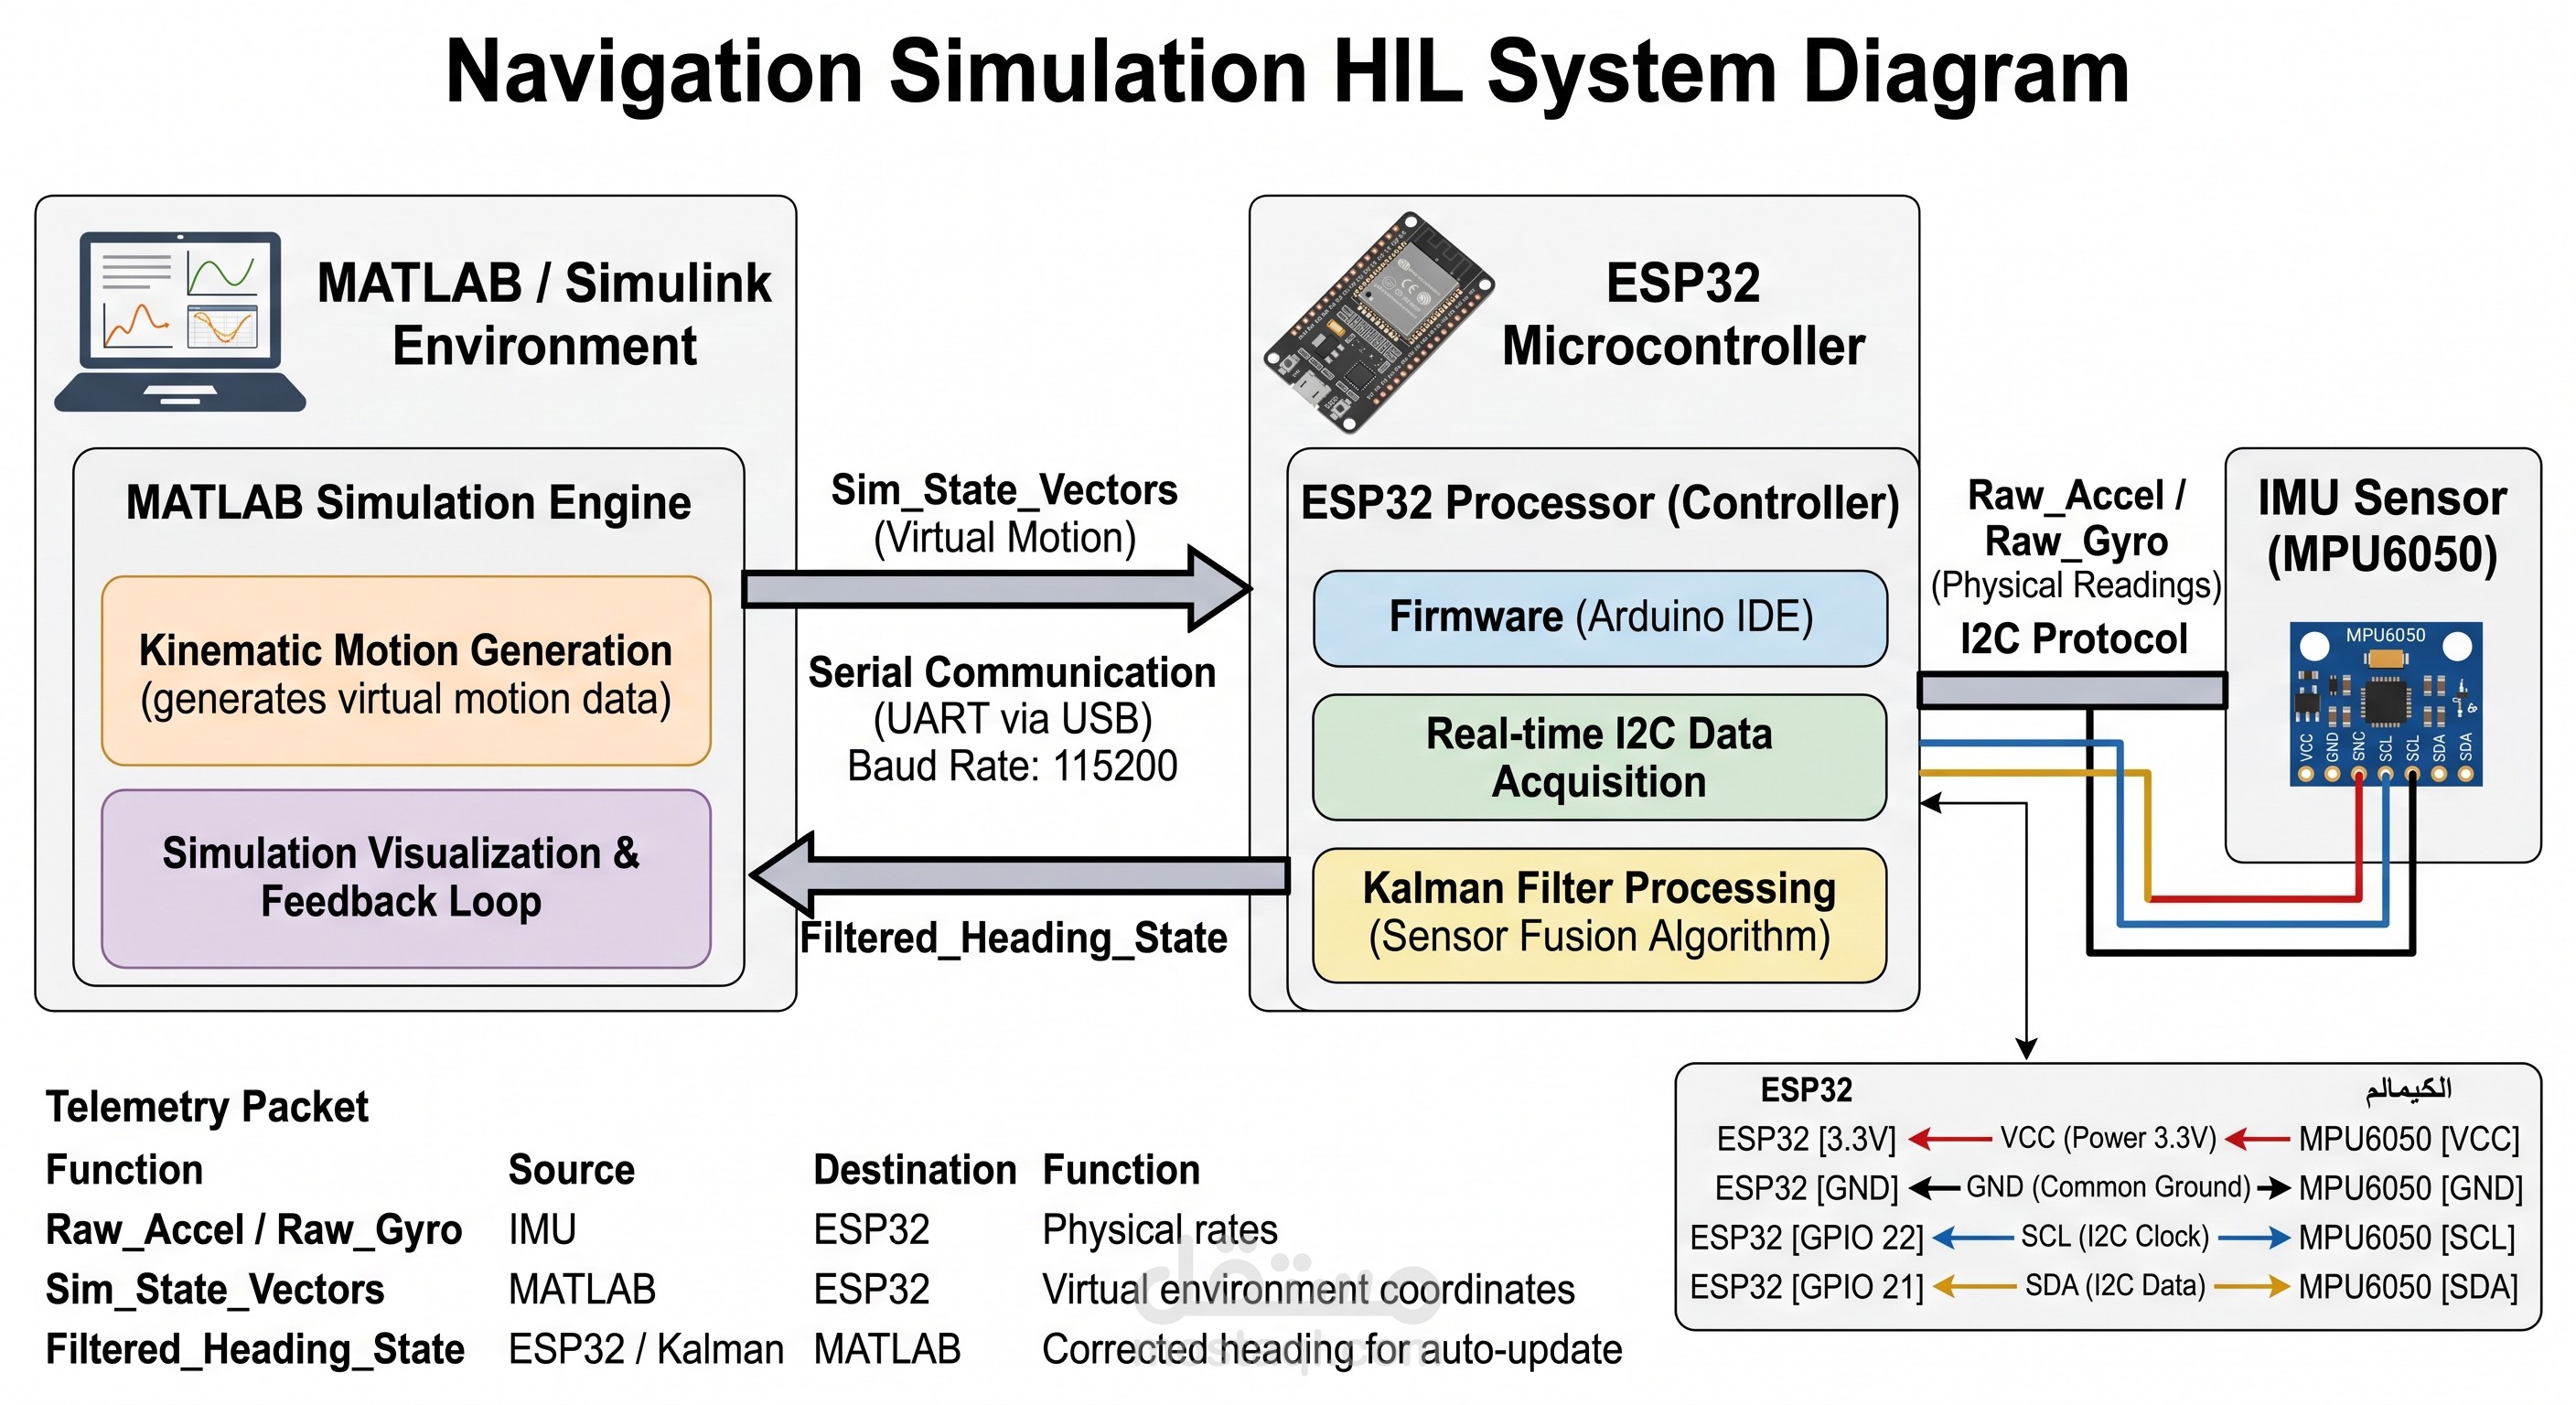
Developed a robust Hardware-in-the-Loop (HIL) simulation framework designed to test and validate autonomous navigation algorithms in dynamic environments before physical deployment.
Technical Implementation
Core Microcontroller:** ESP32 leveraged for real-time processing and communication.
Sensor Fusion:** Integrated an Inertial Measurement Unit (IMU) to capture precise acceleration and angular velocity data.
Algorithmic Optimization:** Implemented a custom Kalman Filter in MATLAB to denoise raw sensor telemetry, achieving high-accuracy state estimation.
Development Environment:** Arduino IDE for firmware development and MATLAB for real-time data visualization and simulation control.
Key Outcomes
Successfully mimicked real-world kinetic motion through a closed-loop HIL testing bench.
Significantly reduced sensor drift and noise, ensuring stable navigation telemetry for autonomous systems.