AERY_ServoControlBoard
تفاصيل العمل
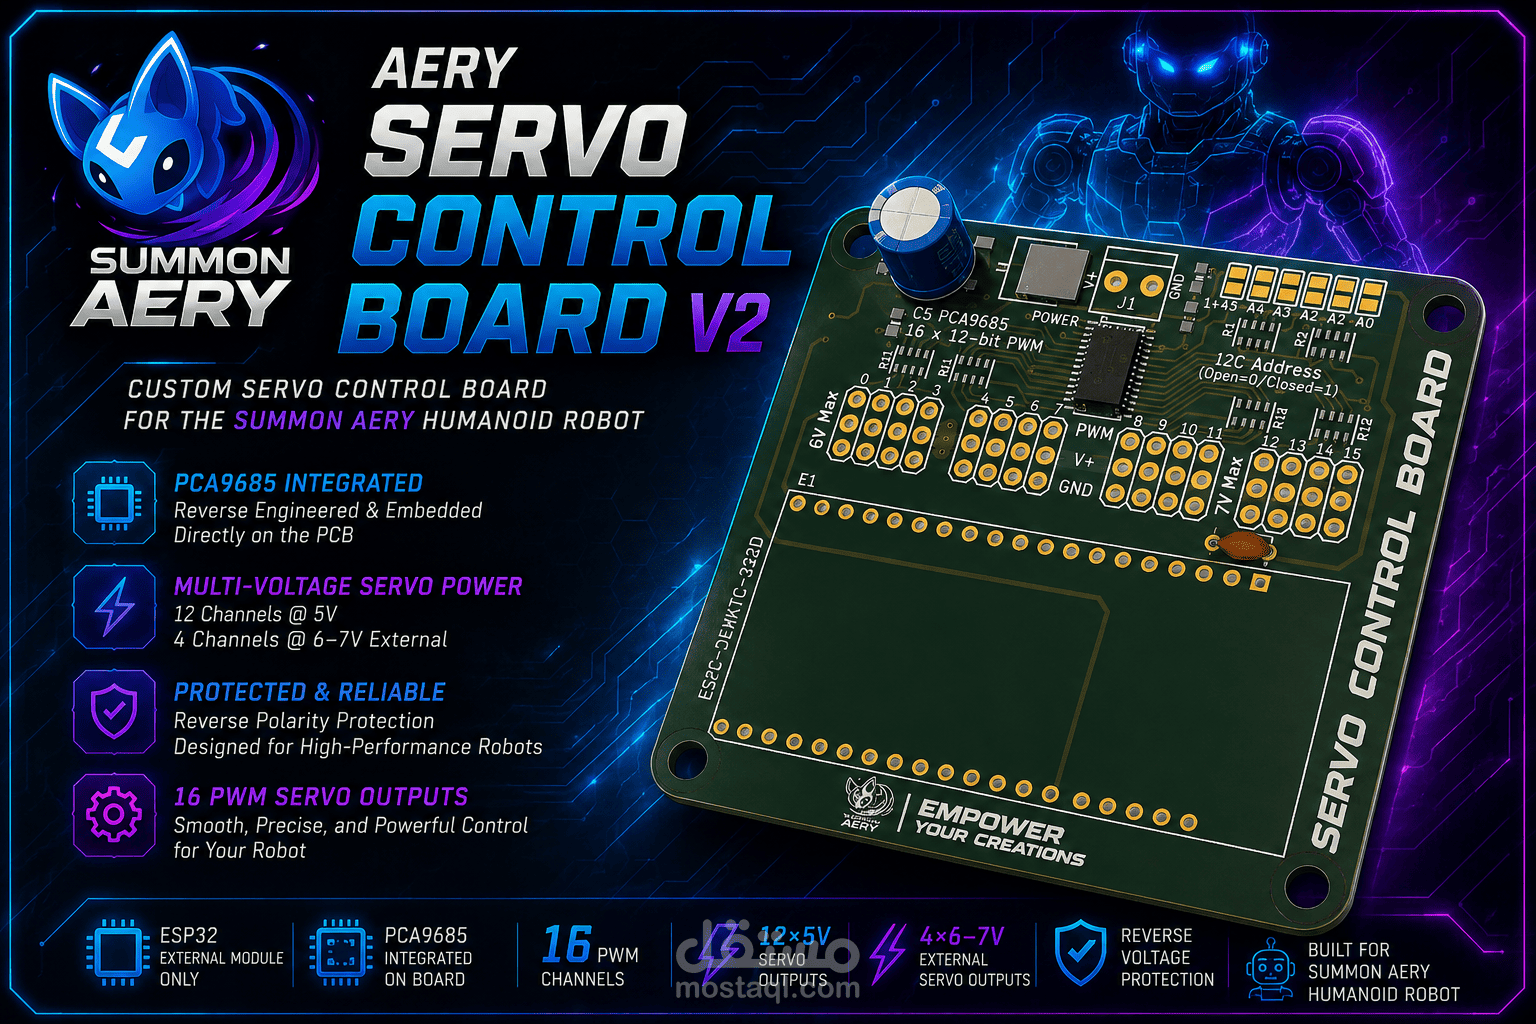
AERY Servo Control Board V2 is a custom 2-layer PCB developed for the Summon AERY Humanoid Robot, designed to control and power 16 servo motors using an ESP32 and an integrated PCA9685 PWM controller.
For this revision, I reverse-engineered the PCA9685 breakout circuit and integrated the required circuitry directly into the PCB, eliminating the need for an external PCA9685 module.
The board features:
ESP32-DEVKITC-32D as the main controller
Integrated PCA9685, 16-channel / 12-bit PWM
16 servo channels
12 × 5V servo outputs
4 × external 6–7V outputs for higher-voltage servos
Separate servo power domains
MOSFET-based reverse-voltage protection
Configurable I²C address
Wide power traces and organized power distribution
2-layer PCB designed in KiCad 10.0.5
The project was a practical exercise in PCB design, reverse engineering, power distribution, embedded systems, and hardware integration, taking the design from an external-module-based architecture to a more integrated custom control board.
Tools & Technologies: KiCad · ESP32 · PCA9685 · I²C · PWM · PCB Design · Embedded Systems · Robotics