AERY Humanoid Robot
تفاصيل العمل
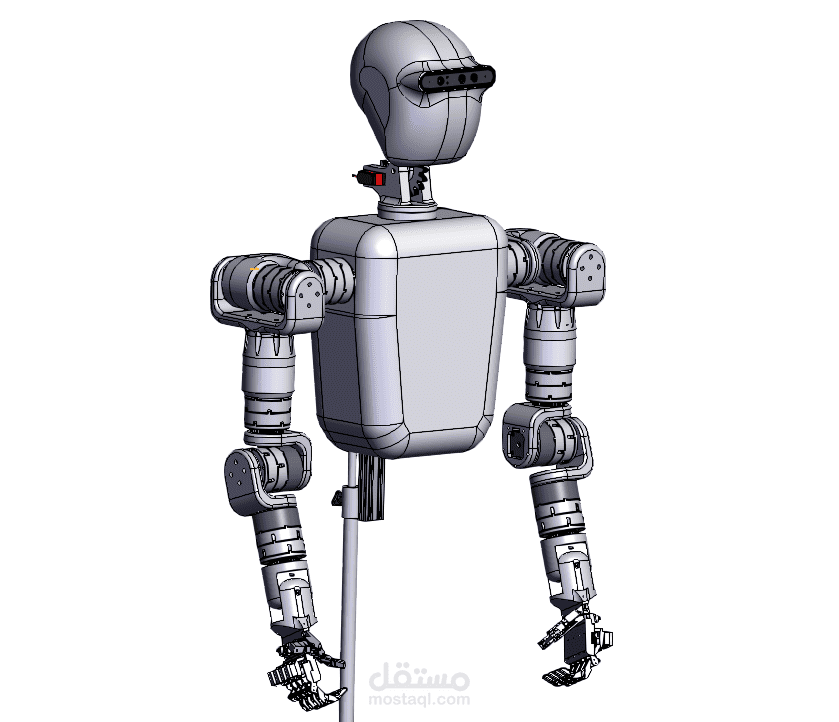
AERY is an intelligent upper-body humanoid robot designed for industrial automation and warehouse operations, including material handling, inventory inspection, sorting, packaging, and production-line tasks.
I worked on the design and development of the robot across multiple engineering domains, including:
⚙️ Mechanical Engineering
Designed the robot structure, joints, and mechanisms from scratch using SolidWorks.
Developed custom planetary gearboxes for NEMA 17 and NEMA 23 stepper motors.
Designed a 24-DOF upper-body robotic platform.
Designed 3D-printed structural components using PETG.
Developed custom housings for the stepper motor drivers.
🔌 Embedded Systems & Electronics
Designed custom PCBs for motion and servo control.
Developed an Arduino Mega-based Motion Board for stepper motor control and encoder feedback.
Integrated 10× AS5600 magnetic encoders through 2× TCA9548A I²C multiplexers.
Designed a custom ESP32-based Servo Control Board for 16 servo channels.
Worked with DM542 and TB6600 stepper drivers.
🤖 Robotics & Control
Implemented the robot's motion-control architecture for steppers and servos.
Developed position-feedback systems using magnetic encoders.
Designed the hardware architecture around the robot's high-load joints and multi-actuator system.
🧠 AI, Computer Vision & ROS
Integrated a 3D depth camera for perception and object detection.
Developed the software architecture around ROS, computer vision, and intelligent decision-making.
Designed the system toward autonomous industrial and warehouse applications.
The project combines mechanical design, embedded systems, electronics, robotics, computer vision, and software integration into one complete robotic platform.
Tools & Technologies:
SolidWorks · KiCad · ESP32 · Arduino Mega · ROS · Python · C/C++ · AS5600 · TCA9548A · PCA9685 · NEMA 17/23 · DM542 · TB6600 · PETG 3D Printing