Precision 4-DOF Robotic Arm: From Kinematic Design to Functional Assembly
تفاصيل العمل
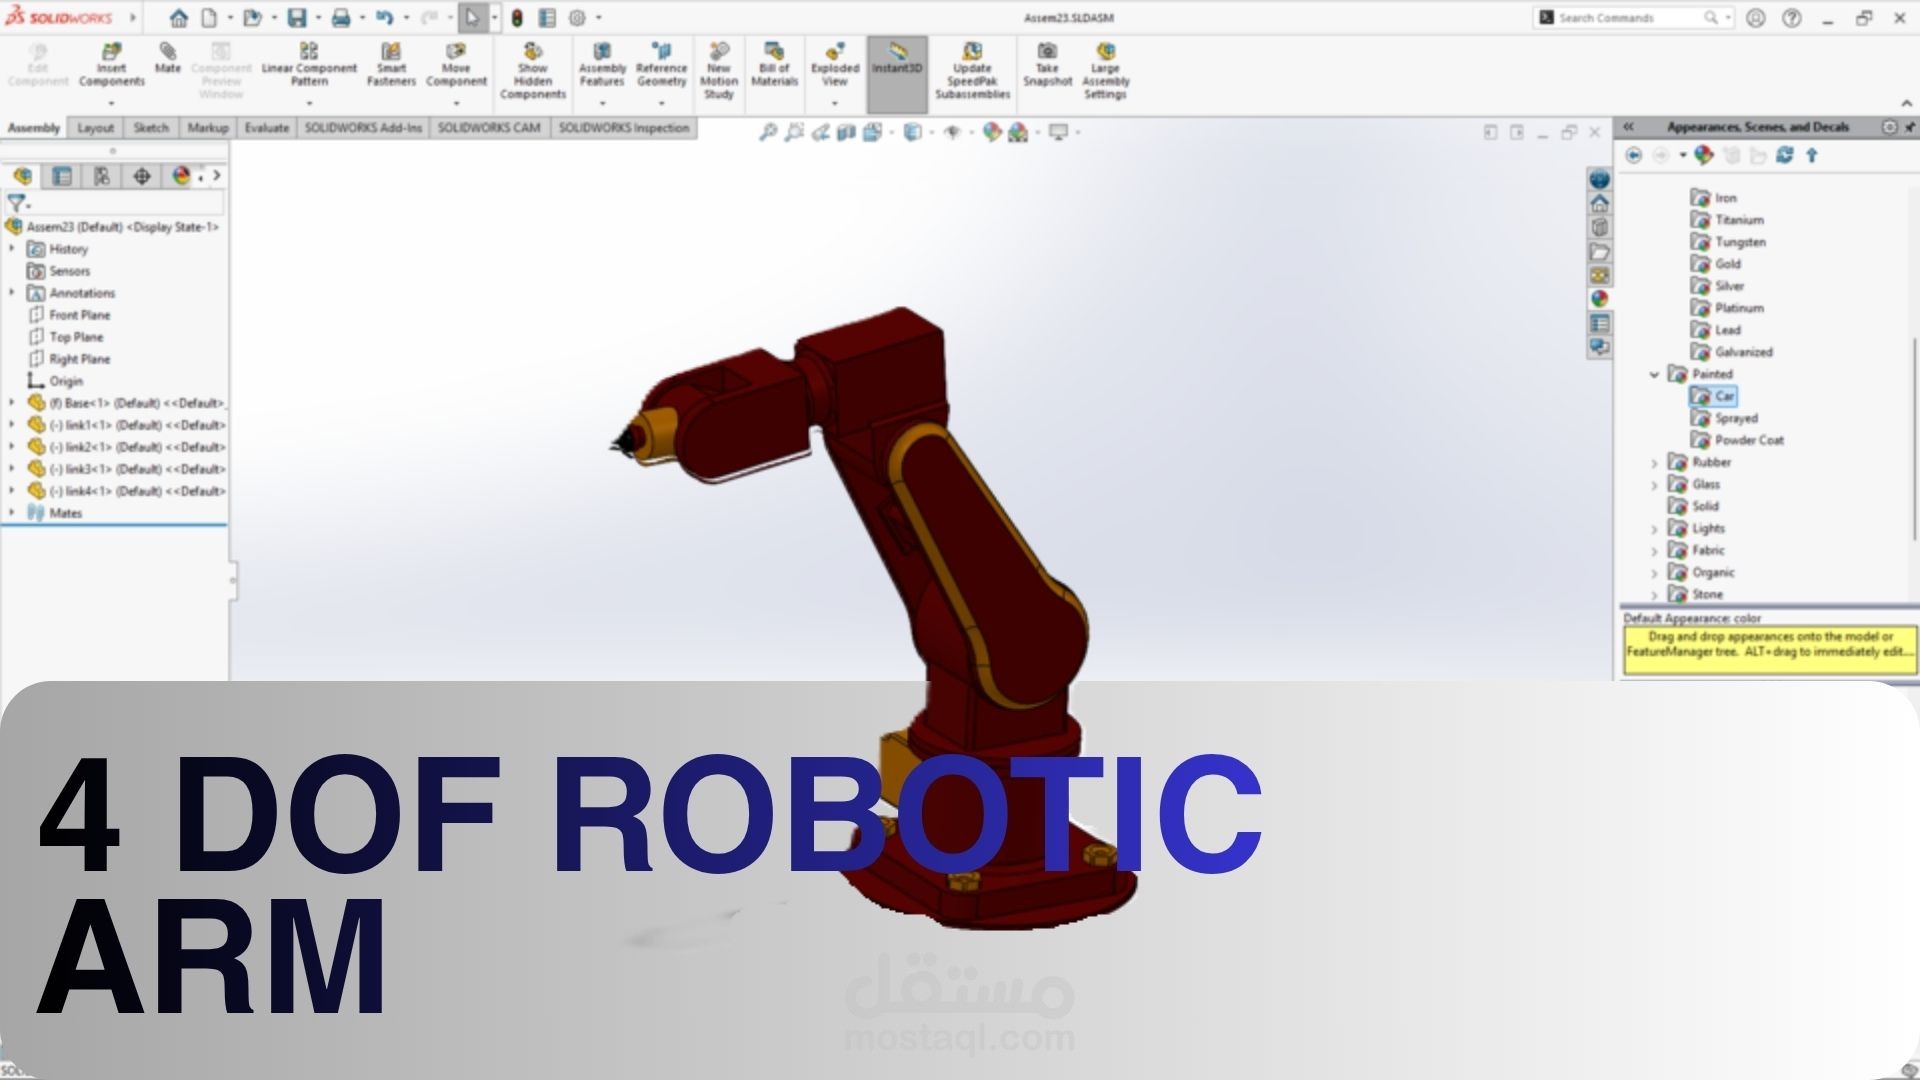
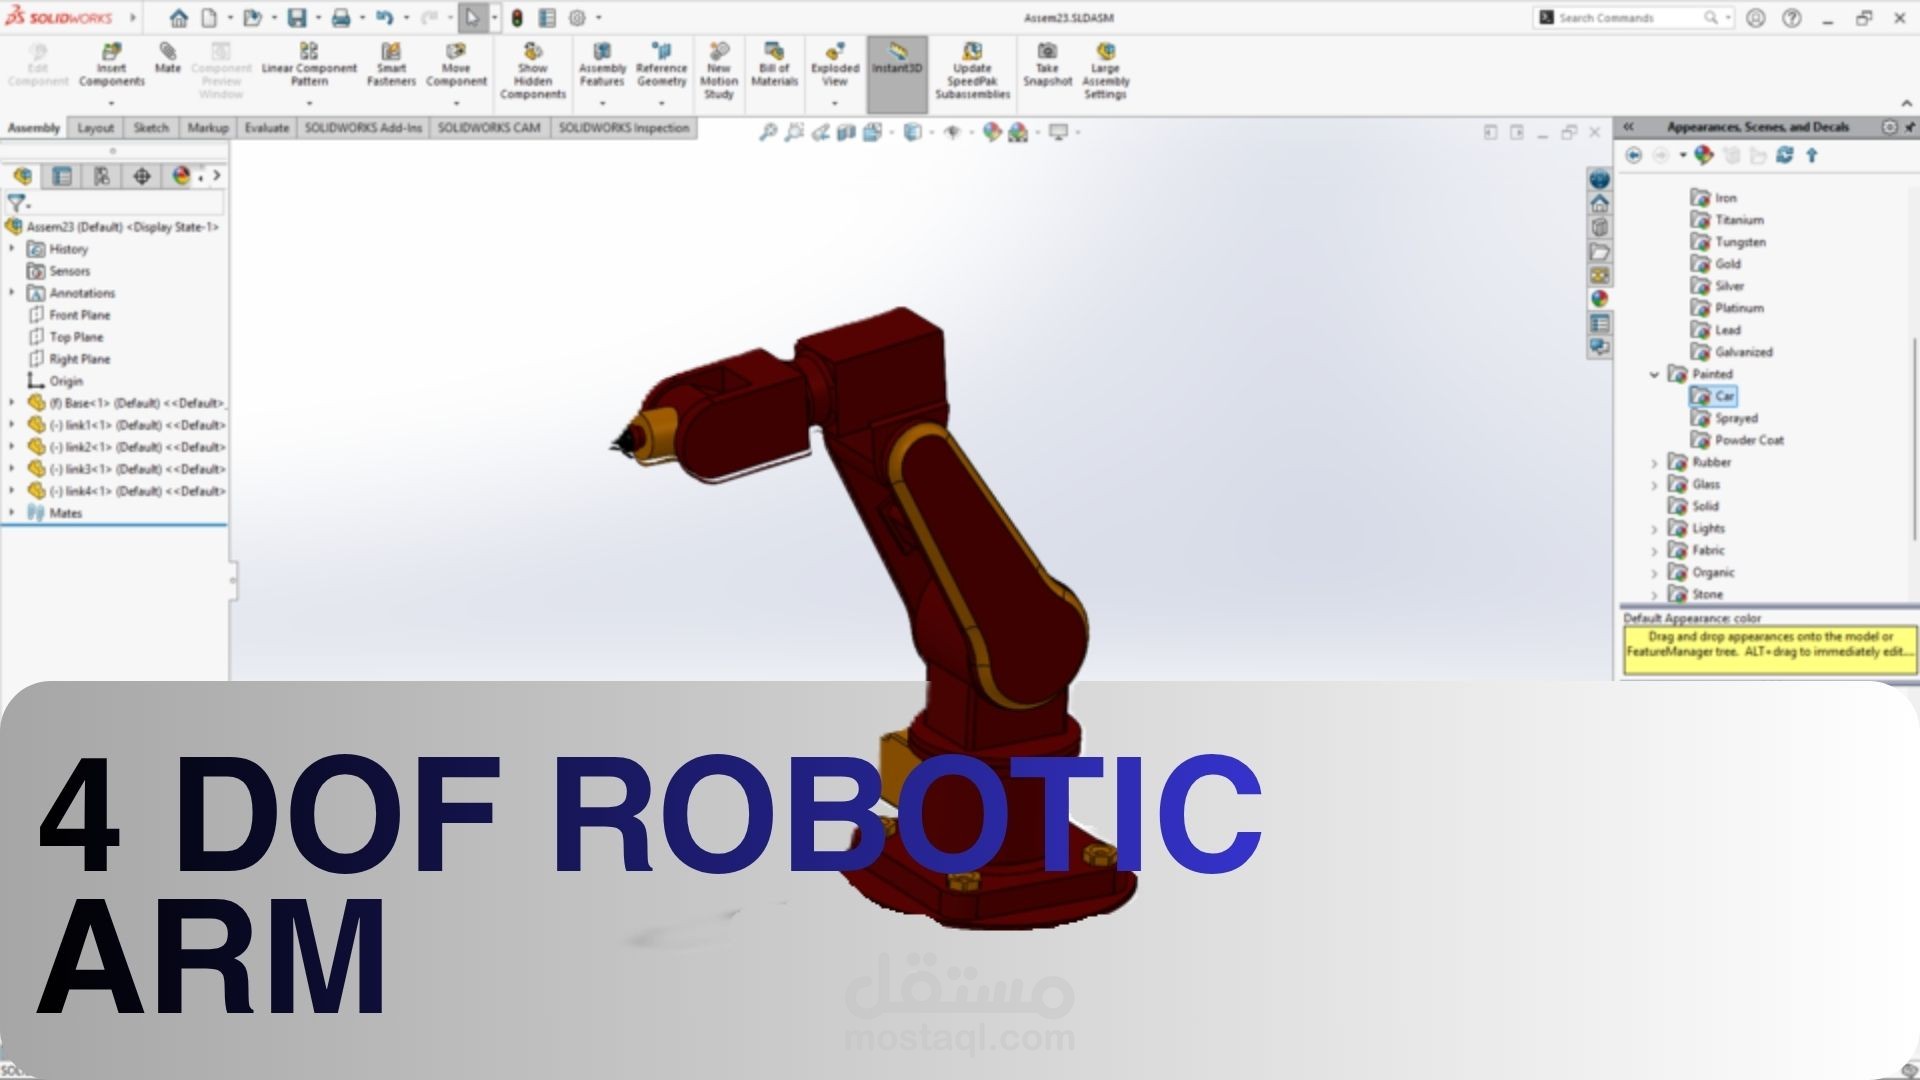
Project Description
Designed and engineered a 4-Degree of Freedom (DOF) robotic arm optimized for educational and light-industrial automation tasks. This project involved the full development lifecycle, starting from initial conceptual sketches to a high-fidelity 3D assembly in SolidWorks.
Key Features:
Kinematic Architecture: Optimized link lengths and joint placements to maximize the workspace while maintaining structural integrity.
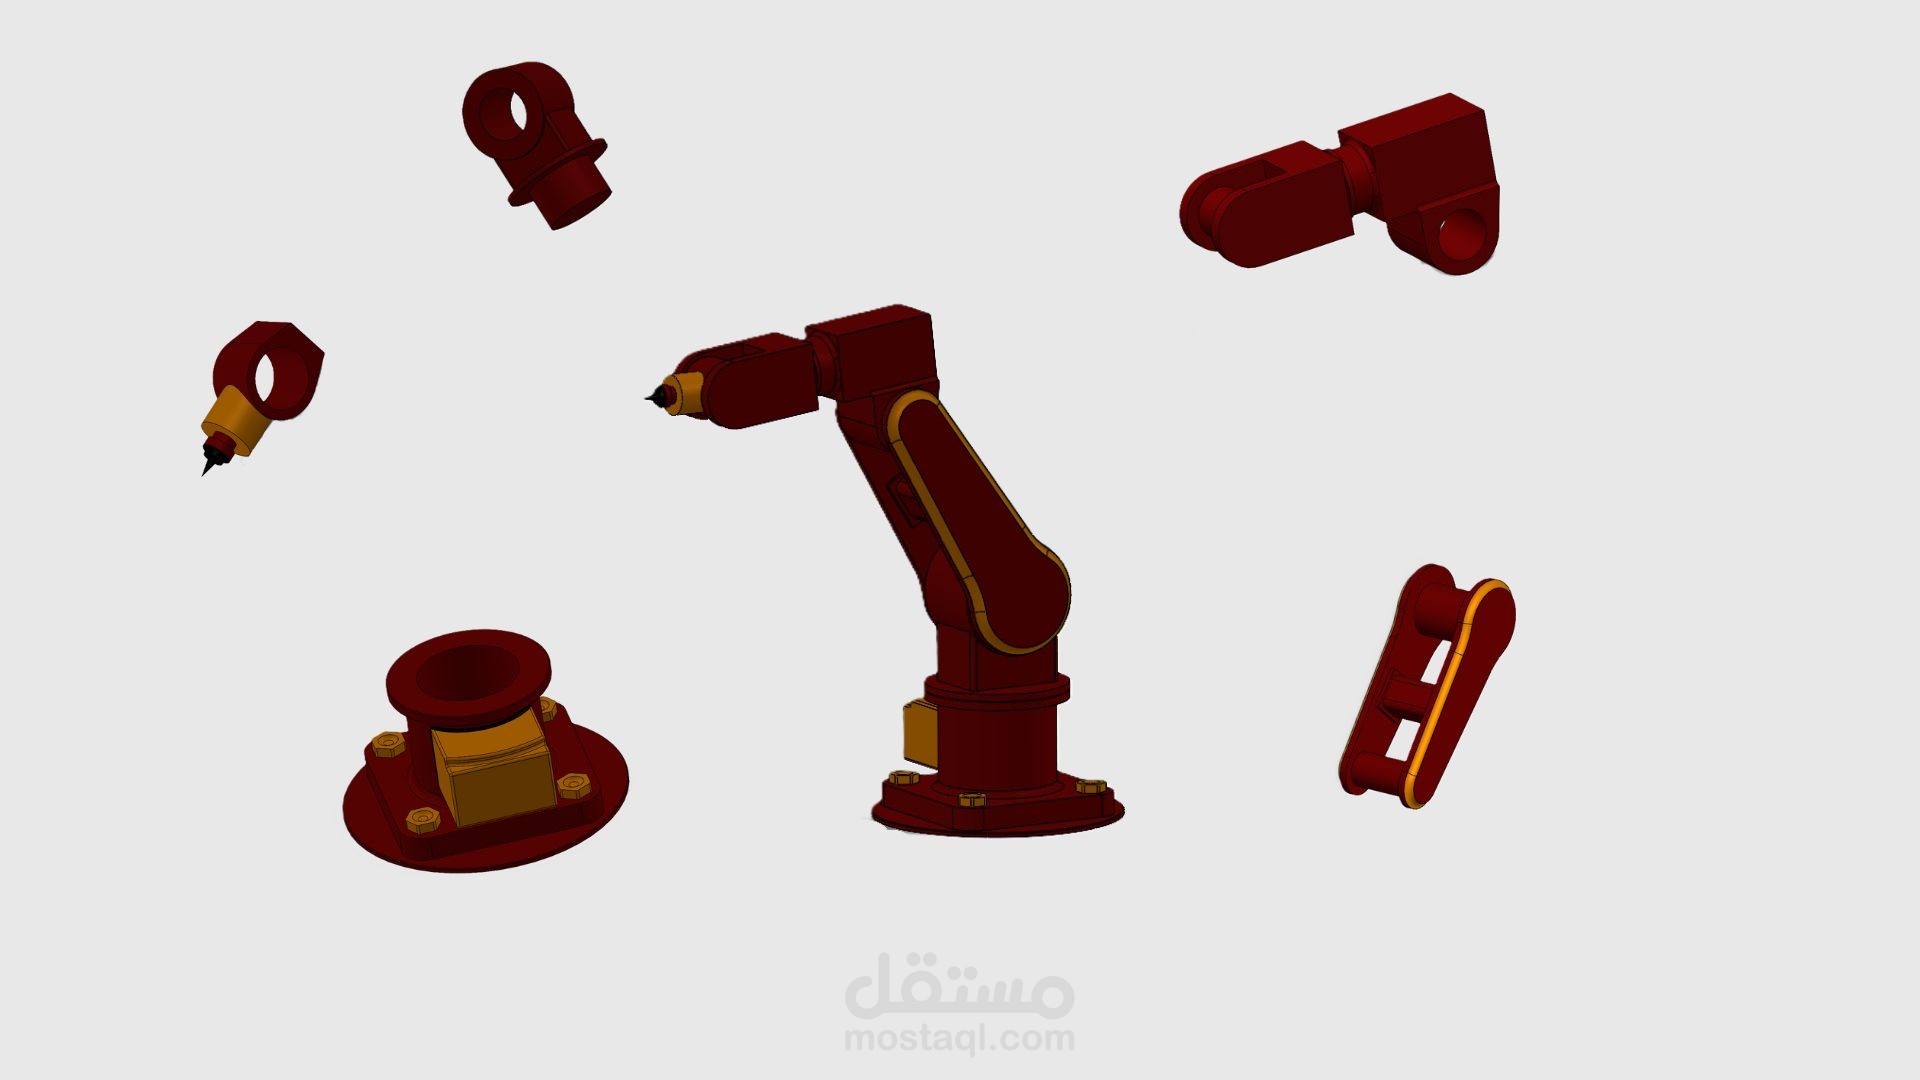
Modular Design: Created an exploded-view assembly to ensure ease of manufacturing and maintenance.
Actuator Integration: Designed custom housings for high-torque servo motors, ensuring precise motion control and minimal backlash.
End-Effector Versatility: Developed an interchangeable tool-head system, currently featuring a precision stylus/gripper attachment.