ROV (Remotely Operated Vehicle) System
تفاصيل العمل
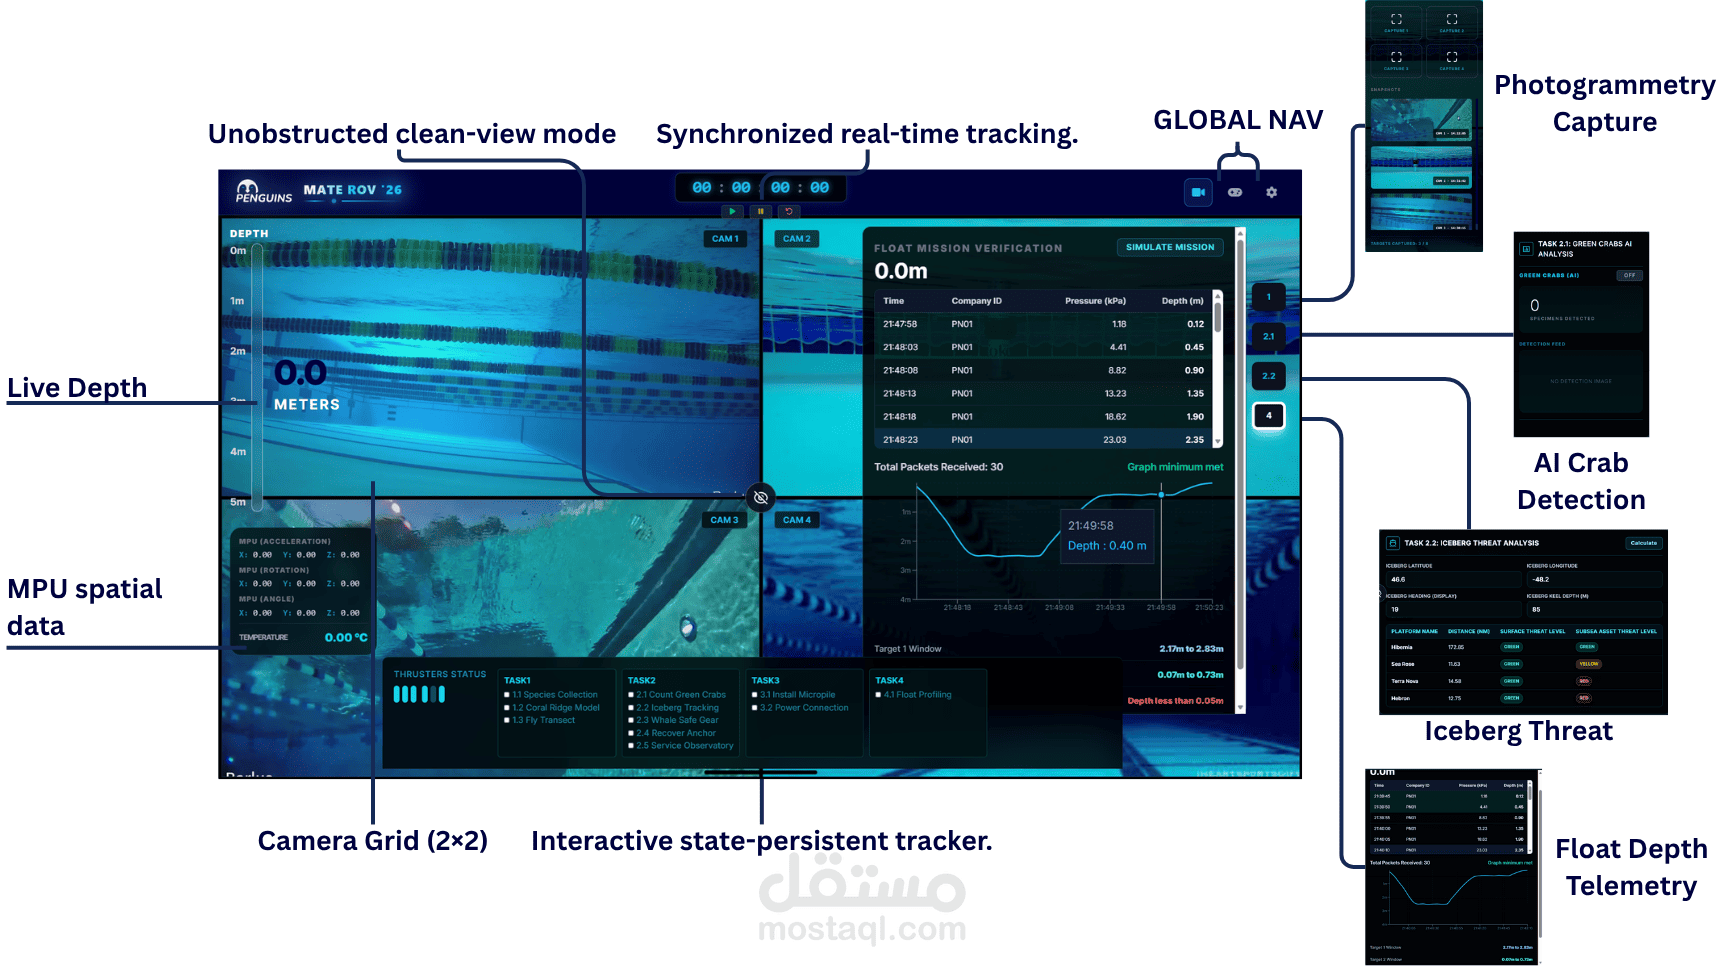
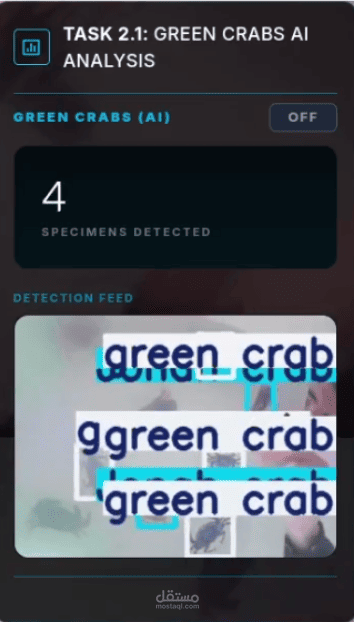
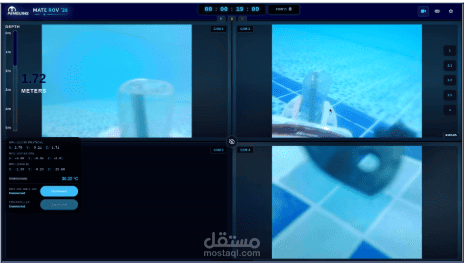
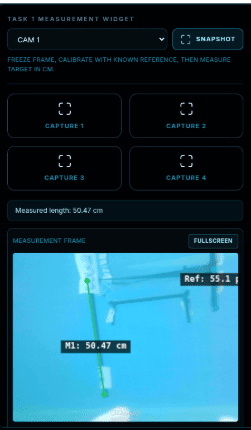
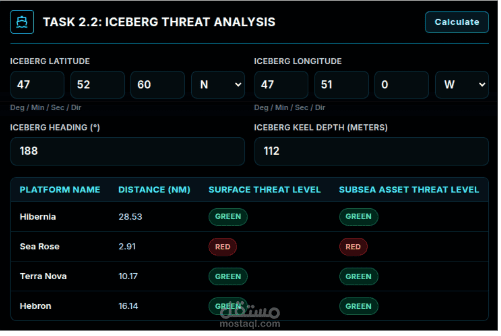
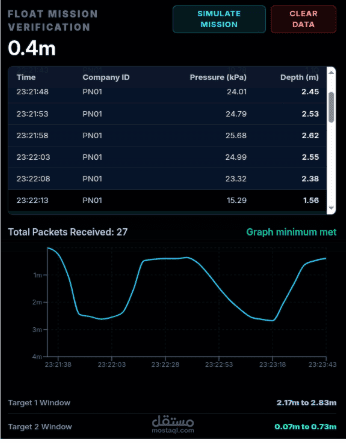
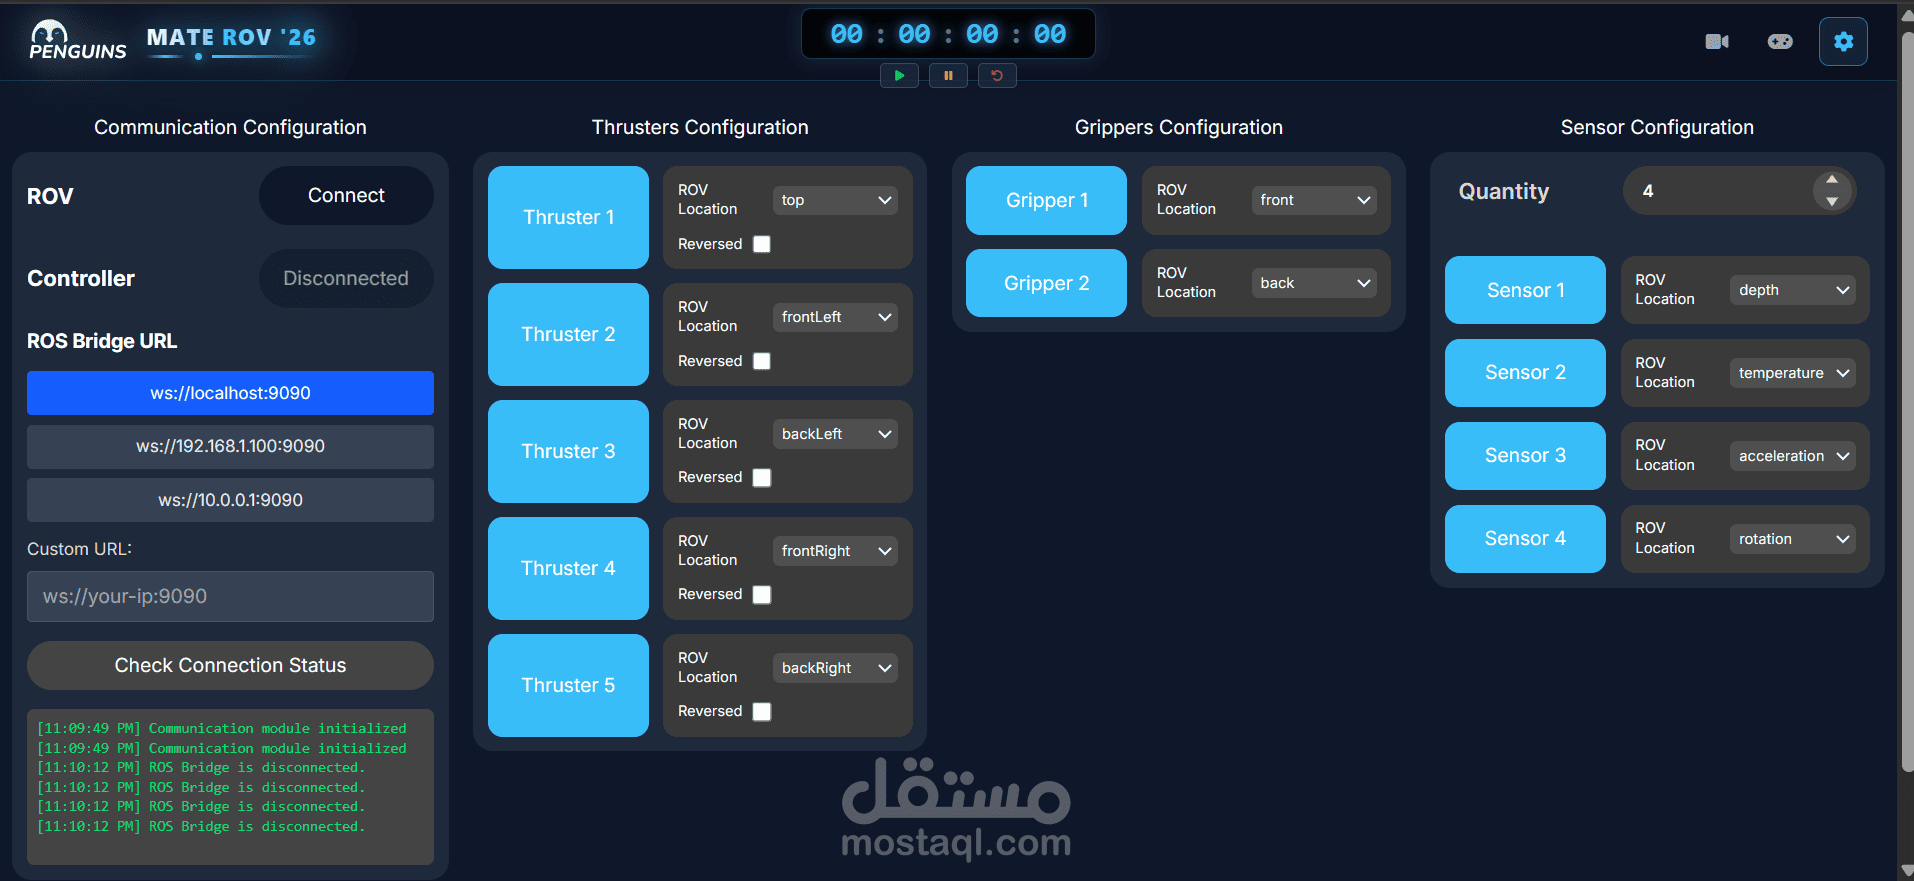
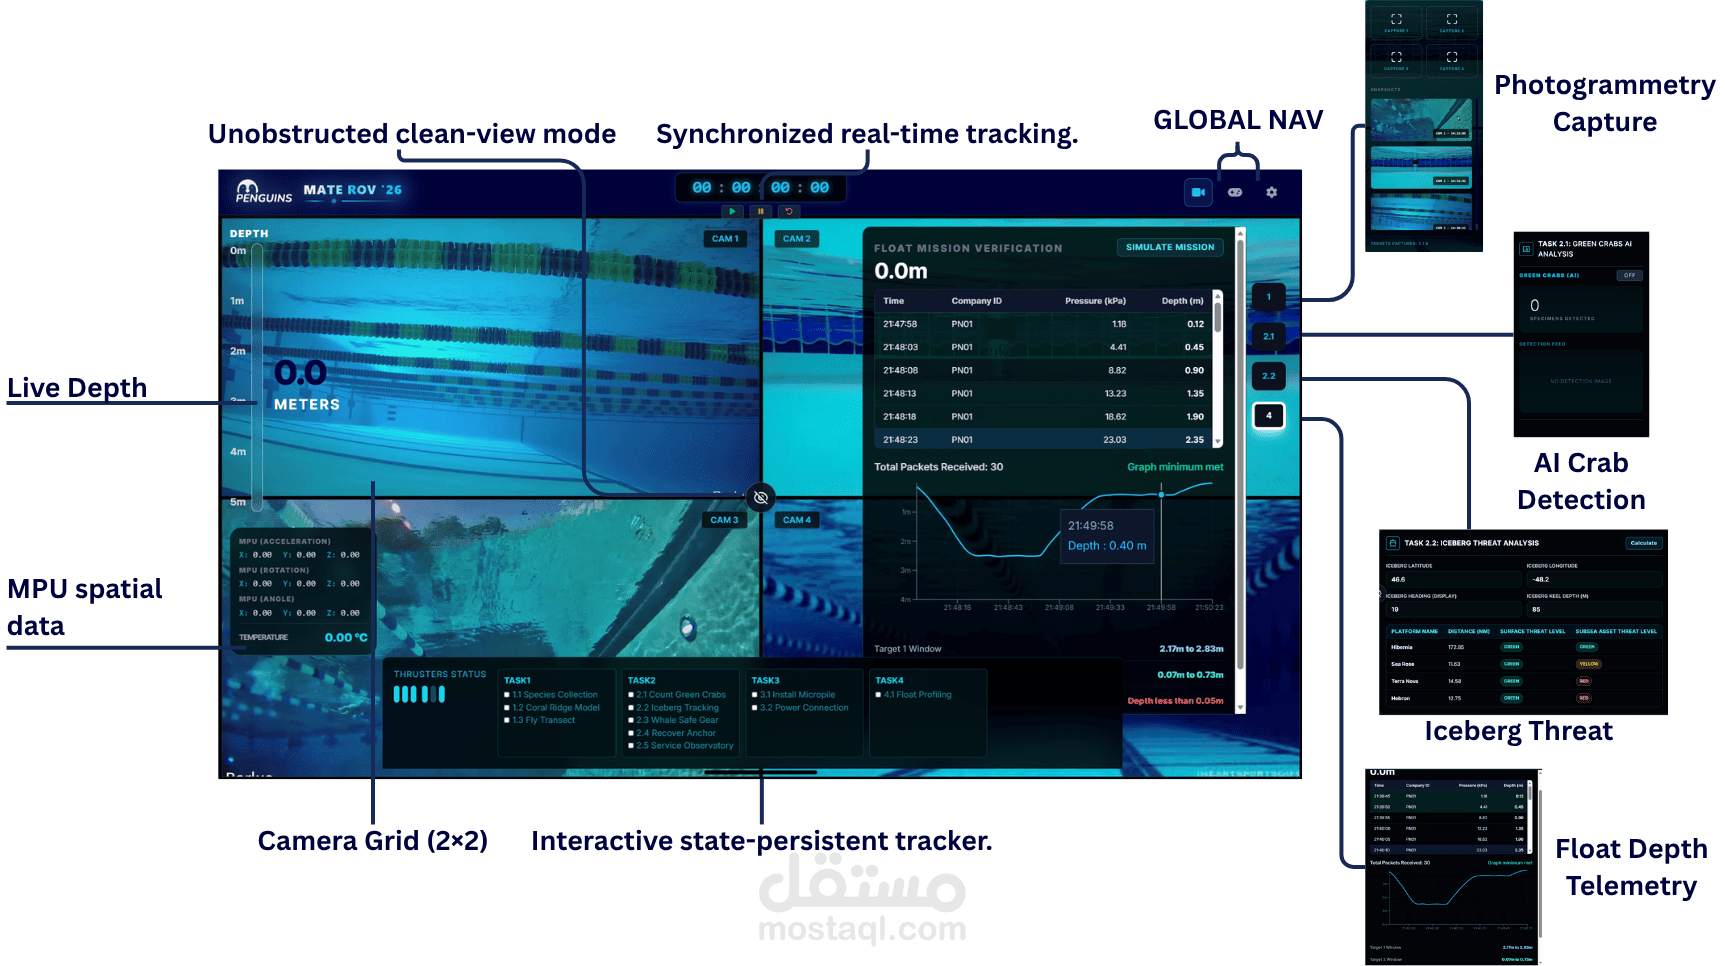
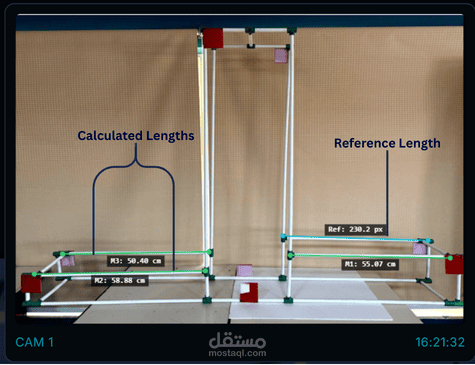
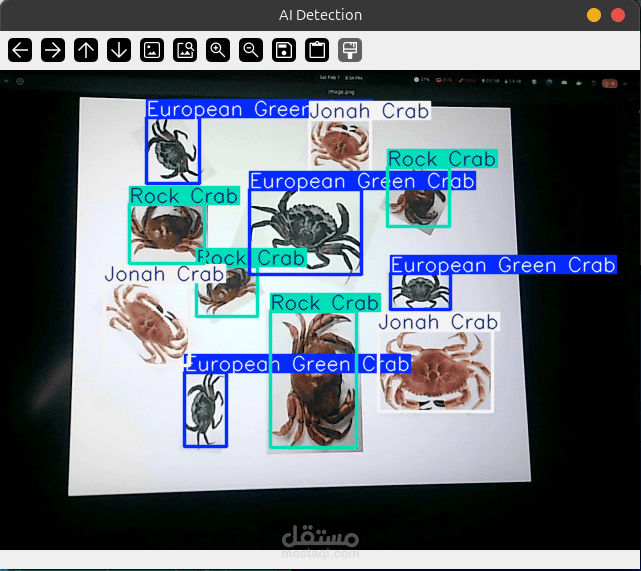
Developed and contributed to a Remotely Operated Vehicle (ROV) system designed for underwater exploration, monitoring, and inspection tasks. The system integrates hardware and software components to enable real-time control, data transmission, and live video streaming between the operator station and the vehicle.
My work focused on system integration, software development, and ensuring stable communication between subsystems. I collaborated with a multidisciplinary team to build a reliable and efficient solution following engineering and software design best practices.
Key features include:
Real-time control and navigation of the ROV
Live video streaming from onboard cameras
Sensor data collection and monitoring
Stable communication between surface control station and vehicle
Modular and scalable system architecture
Team-based development and integration